Ahsan Tanveer
Doctoral Candidate, Intelligent Biomimetic Design Lab, Peking University.

Lab 1038, ENN Building
Zhongguancun N Ave, Haidian
Beijing, China 100871
I am currently a doctoral candidate under Prof. Guangming Xie at the School of Advanced Manufacturing and Robotics, Peking University, and a visiting research fellow at the Max Planck Institute of Animal Behavior, hosted by Dr. Liang Li. I am also a ZUKOnnect Fellow at the Zukunftskolleg, affiliated with the Department of Biology/Centre for the Advanced Study of Collective Behaviour, University of Konstanz.
Previously, I was a lecturer at the Institute of Avionics and Aeronautics (IAA), Air University, Islamabad. I obtained my master’s degree in mechanical engineering from the GIK Institute of Engineering Sciences and Technology (GIKIEST), Swabi, in 2021. During my masters, I was affiliated with the Vibrational Dynamics and Controls (VDC) Lab, advised by Prof. Sarvat M. Ahmad. I received my bachelor’s degree in mechanical engineering from the University of Engineering & Technology (UET), Peshawar, in 2019, advised by Prof. Mohammad A. Irfan. I have also worked at the National University of Sciences and Technology (NUST), Pakistan, and at the Interdisciplinary Research Center for Intelligent Manufacturing and Robotics (IRC-IMR), King Fahd University of Petroleum and Minerals, Saudi Arabia.
My research focuses on bio-inspired robotics, control, and robot learning, particularly for soft and continuum robots operating underwater. I am particularly interested in combining physics-based modeling, intelligent control, and multimodal sensing to improve the robustness, adaptability, and efficiency of robotic manipulation in challenging underwater environments.
Current and future directions of my work include:
- Soft-fluidic actuator design through physics-based modeling, optimization, and data-driven methods
- Modeling and control of highly nonlinear soft and continuum robotic systems for underwater manipulation
- Robot learning and reinforcement learning for robust control, adaptation, and policy recovery
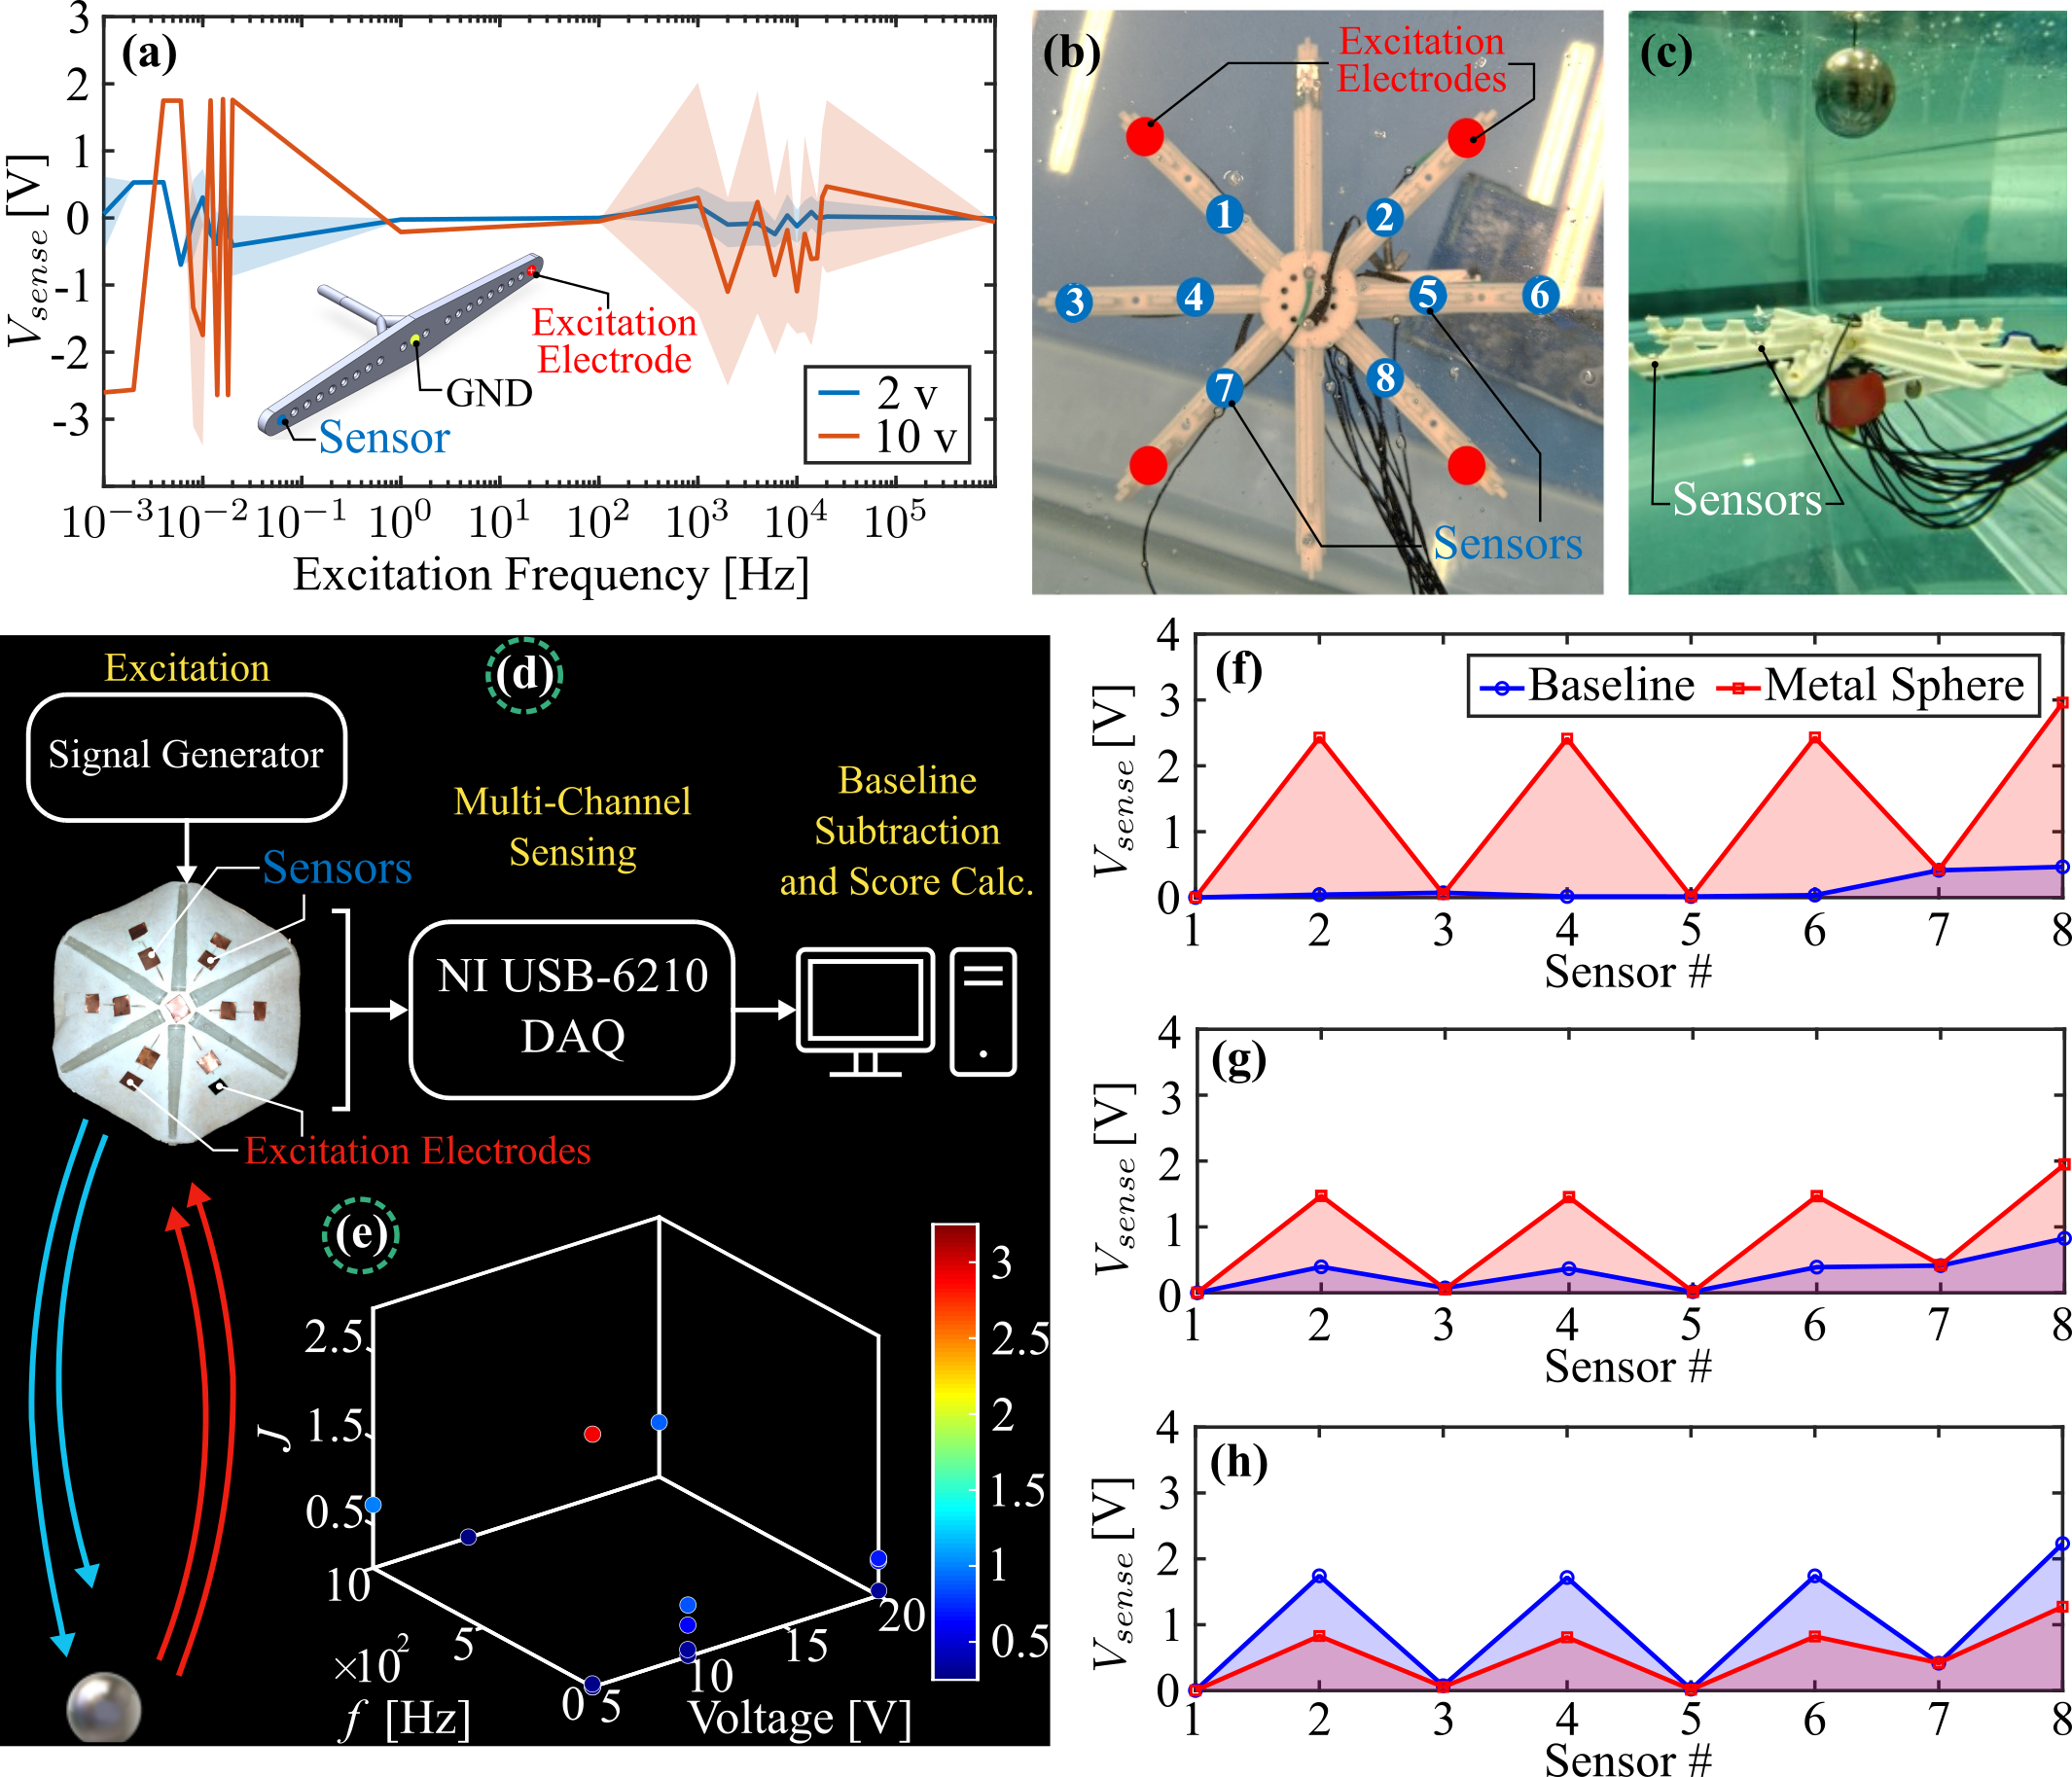
- Bio-inspired sensing mechanisms, including electrosensing, for underwater perception and pre-contact interaction
- Autonomous marine robotic systems with learning-enabled control and embodied intelligence
Please feel free to reach out, if you would like to talk about my work or discuss something of mutual interest.
news
| May 19, 2026 | Our extended abstract on electric sensing as pre-contact cue for underwater soft robotic manipulation got accepted for poster presentation in Workshop on Manipulation Robustness at ICRA 2026. |
|---|---|
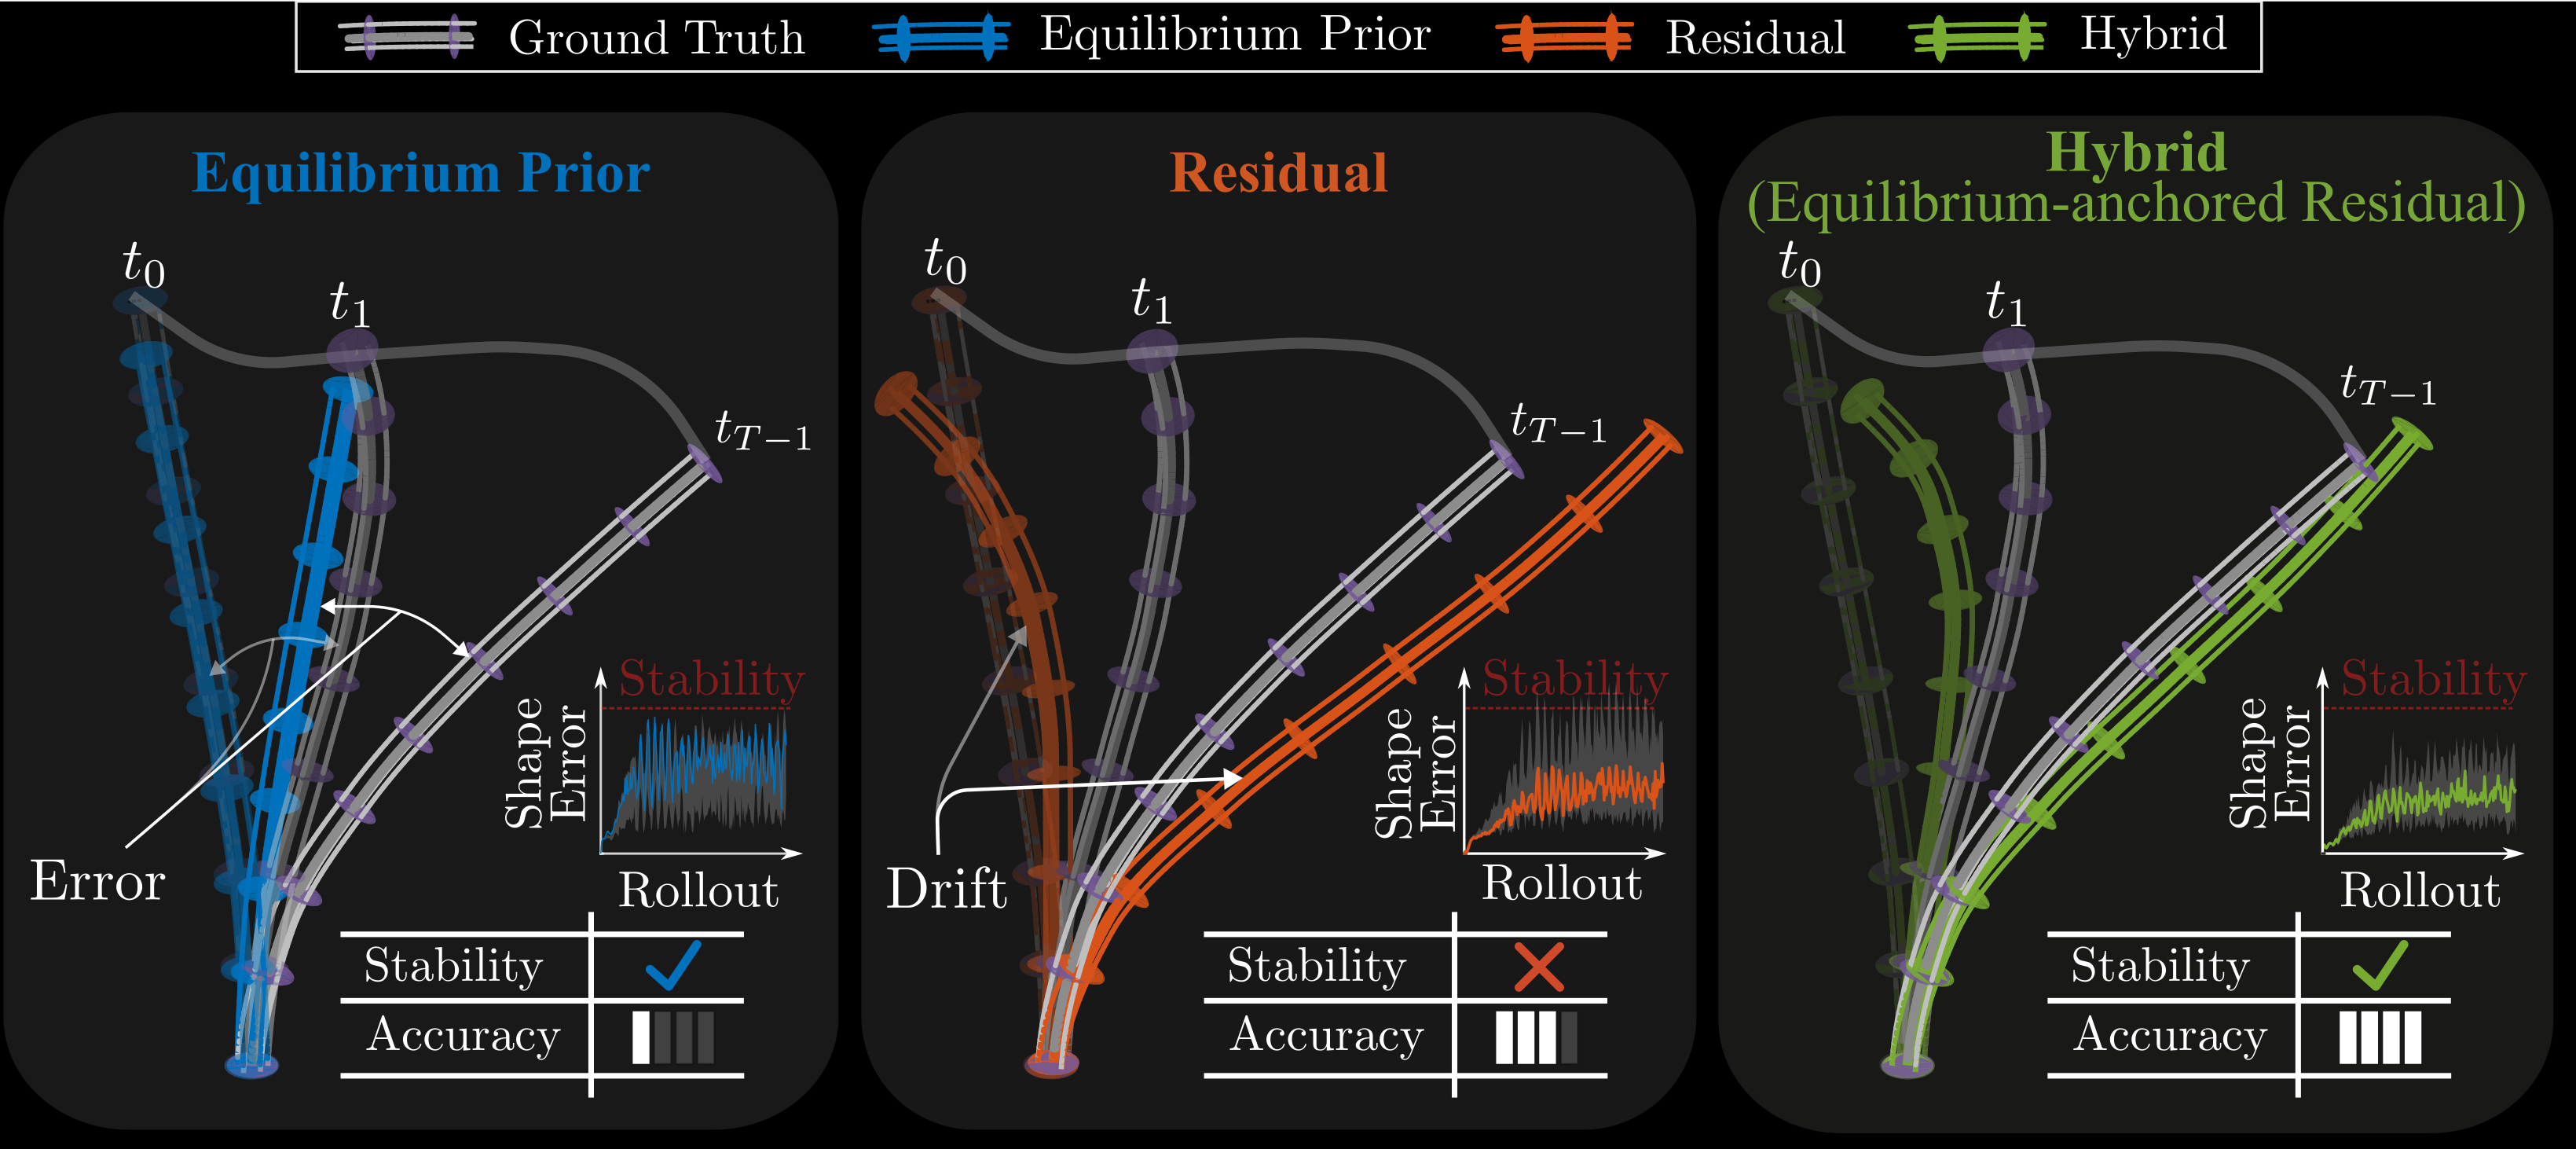
| Apr 27, 2026 | Our latest work on stabilizing rollouts for 3D continuum robots got accepted in Control \& Dynamics track at RSS 2026. |
| Apr 26, 2026 | I am selected for the prestigious ZUKOnnect Fellowship at the University of Konstanz. |
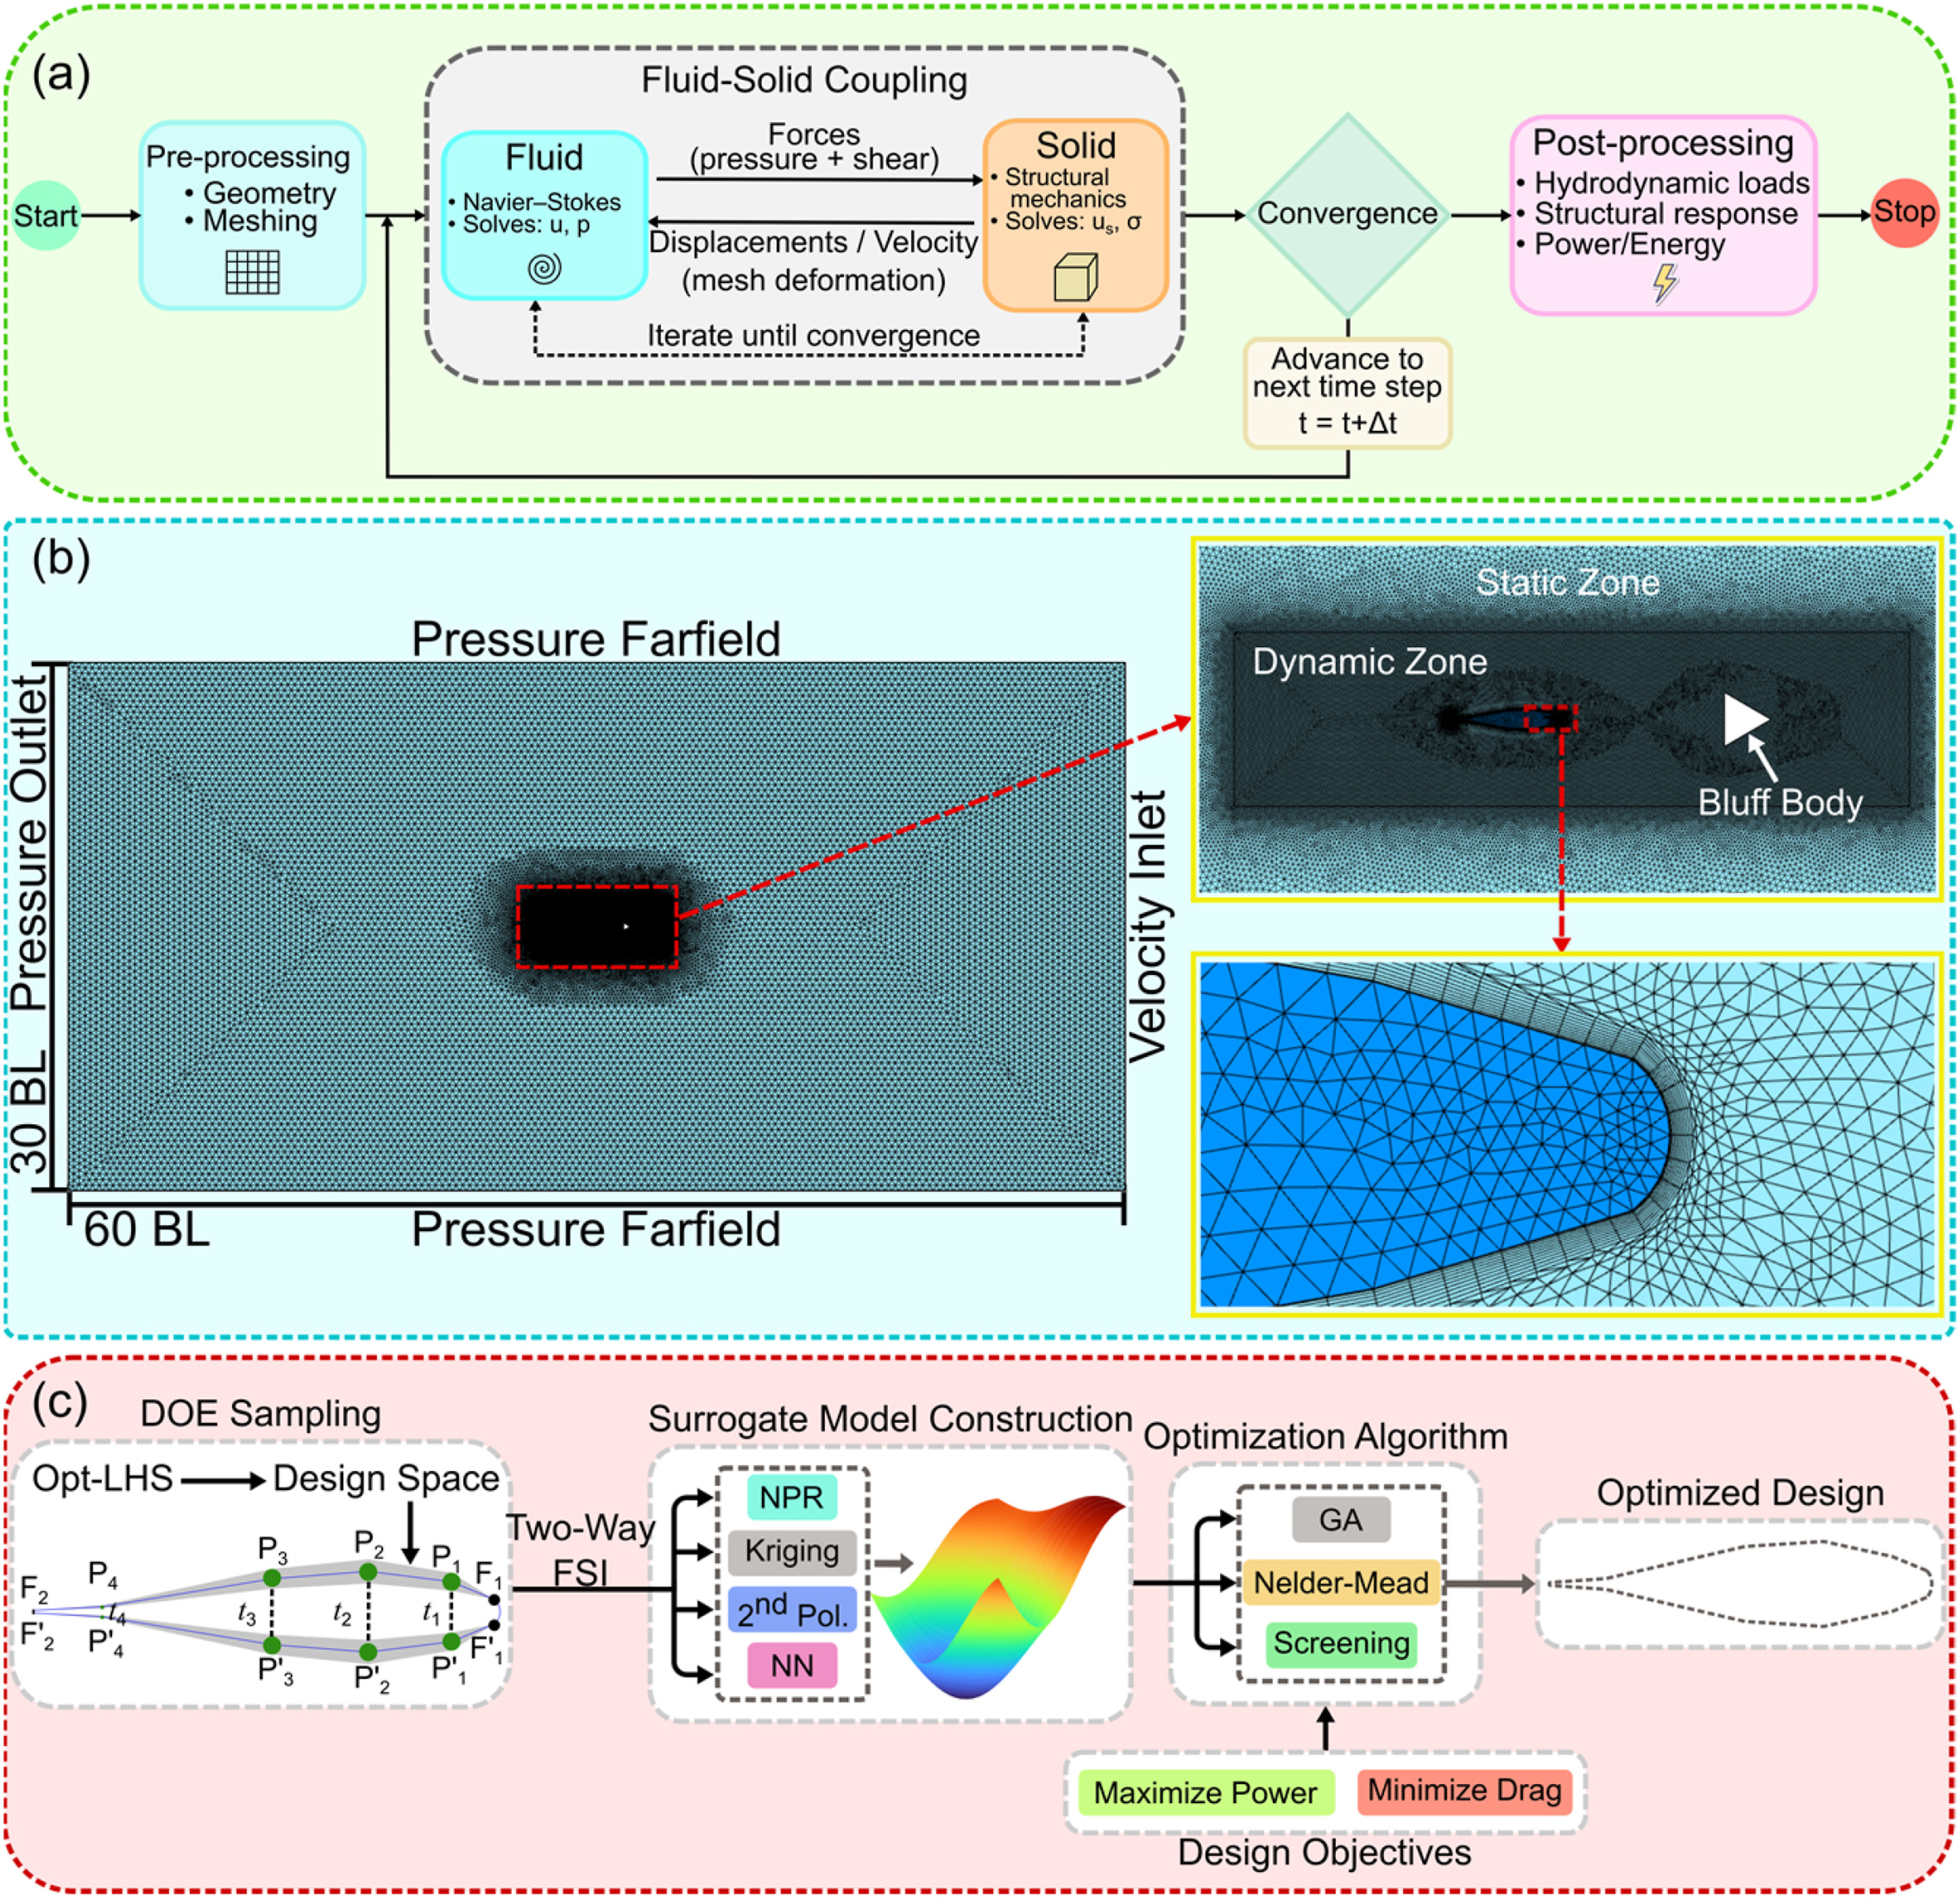
| Mar 21, 2026 | Our latest paper on geometric optimization of a hydrofoil for energy harvesting was just accepted in Energy. |
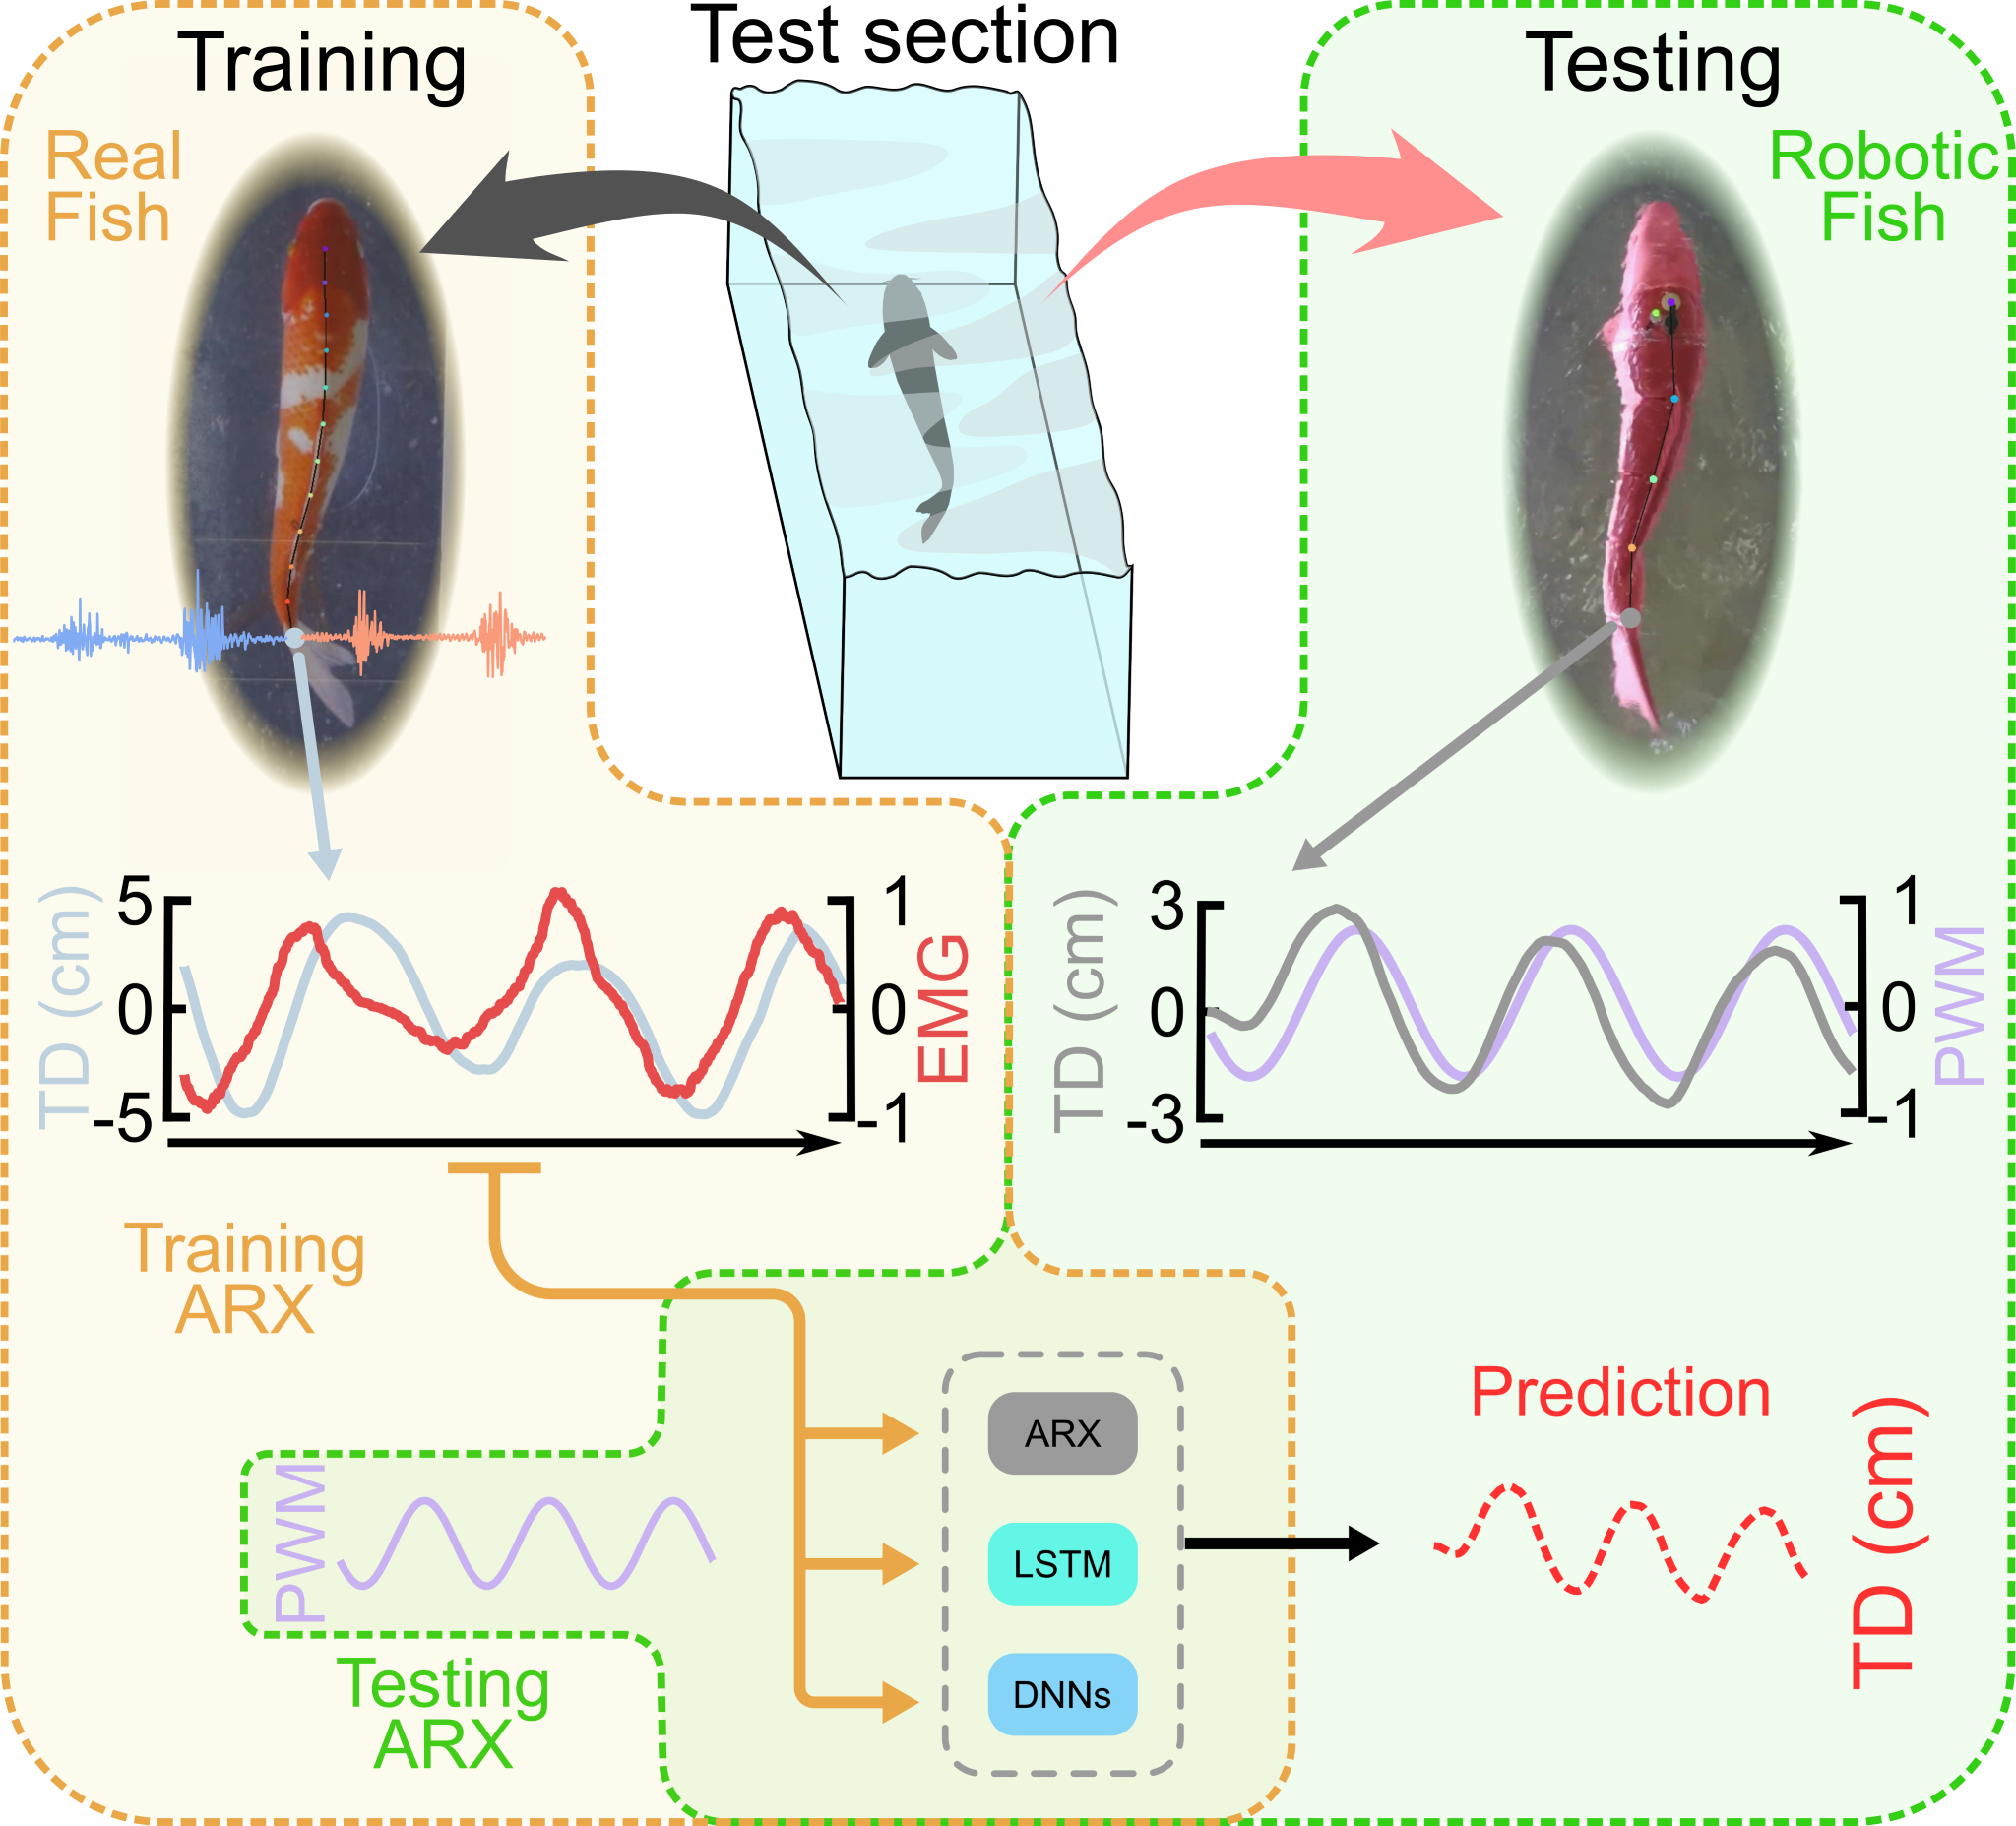
| Feb 19, 2026 | Our latest paper on EMG-driven telemetry and inference system for fish was just accepted in Advanced Intelligent Systems. |